
Tuesday 25 March 2025
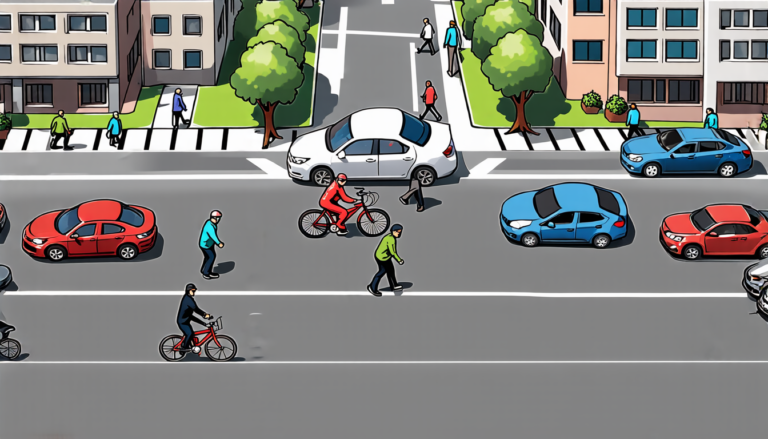
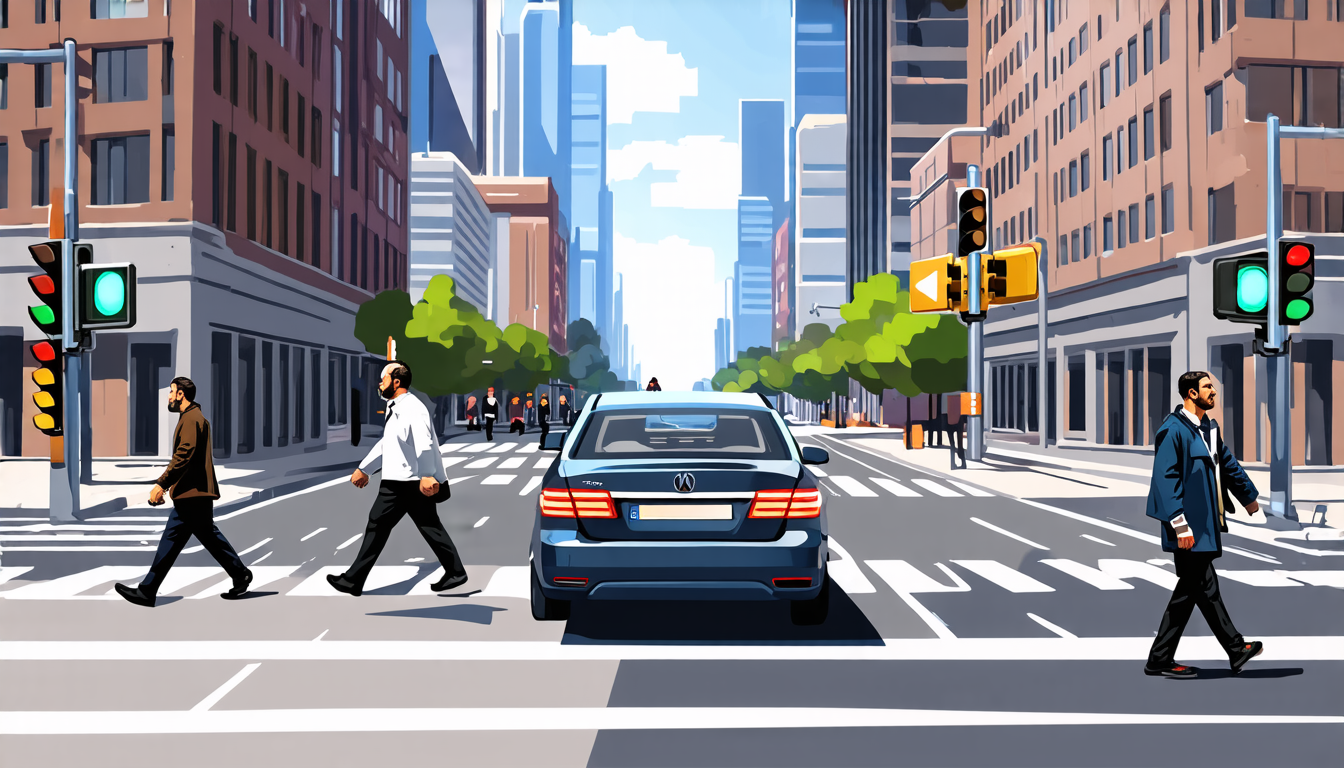
The quest for autonomous vehicles that can navigate complex city streets has long been a challenge for researchers and engineers. One of the key obstacles is integrating human-like reasoning into these systems, allowing them to anticipate and respond to unexpected situations on the road.
A recent paper explores this problem by examining how knowledge-based approaches can be used to improve trajectory prediction and planning in autonomous driving systems. The authors identify several methodologies that incorporate domain knowledge, traffic rules, and common sense reasoning into these systems, ranging from purely symbolic representations to hybrid neuro-symbolic architectures.
One of the most promising techniques is the use of formal logic programming languages, which allow for precise specification of traffic rules and regulations. This approach enables autonomous vehicles to reason about complex scenarios, such as unexpected pedestrian movements or sudden lane changes, in a more human-like way.
Another key innovation is the integration of large language models into autonomous driving systems. These models can be trained on vast amounts of data, including text descriptions of driving scenarios, to learn patterns and relationships that humans take for granted. By combining these models with formal logic programming languages, researchers hope to create a more comprehensive and accurate understanding of the world.
The authors also highlight the importance of knowledge representation in autonomous driving systems. This involves encoding traffic rules and regulations in a way that is easily understood by both humans and machines. For example, using logical statements to describe traffic signals or road signs can help vehicles make decisions in real-time.
One of the most intriguing aspects of this research is its potential implications for safety and reliability. By incorporating human-like reasoning into autonomous driving systems, researchers hope to reduce the risk of accidents caused by unexpected events on the road. This could involve not only anticipating pedestrian movements but also responding appropriately to unexpected obstacles or vehicle malfunctions.
The paper’s findings suggest that a combination of formal logic programming languages, large language models, and knowledge representation can help create more intelligent and responsive autonomous driving systems. While there is still much work to be done in this area, the authors’ research offers promising insights into how humans and machines can collaborate to improve road safety.
In recent years, researchers have made significant progress in developing autonomous vehicles that can navigate complex city streets with ease. However, one of the key challenges remains integrating human-like reasoning into these systems, allowing them to anticipate and respond to unexpected situations on the road.
Cite this article: “Unlocking Human-Like Reasoning in Autonomous Vehicles”, The Science Archive, 2025.
Autonomous Vehicles, Human-Like Reasoning, Trajectory Prediction, Planning, Formal Logic Programming Languages, Large Language Models, Knowledge Representation, Traffic Rules, Regulations, Safety, Reliability